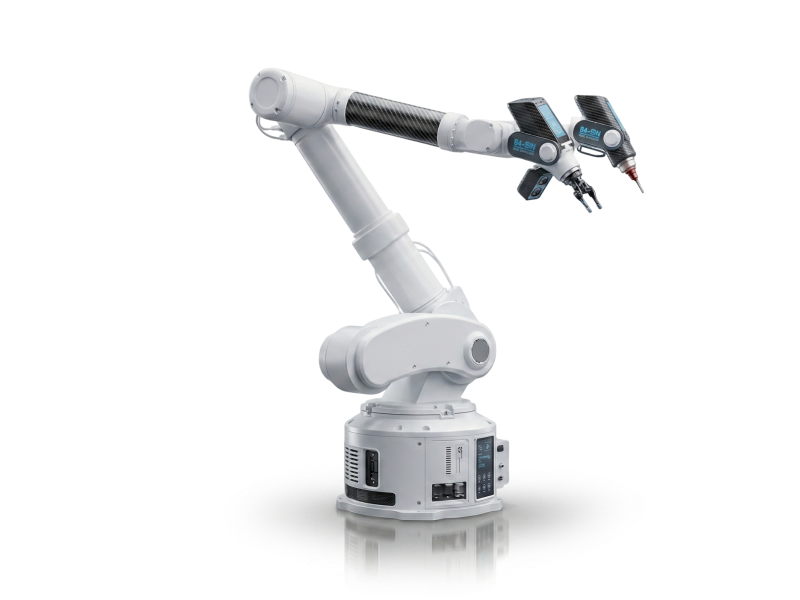
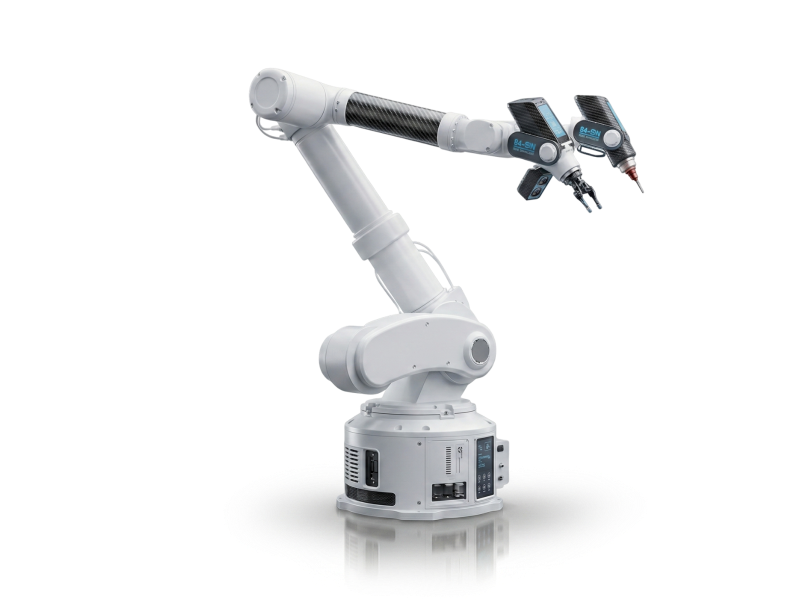
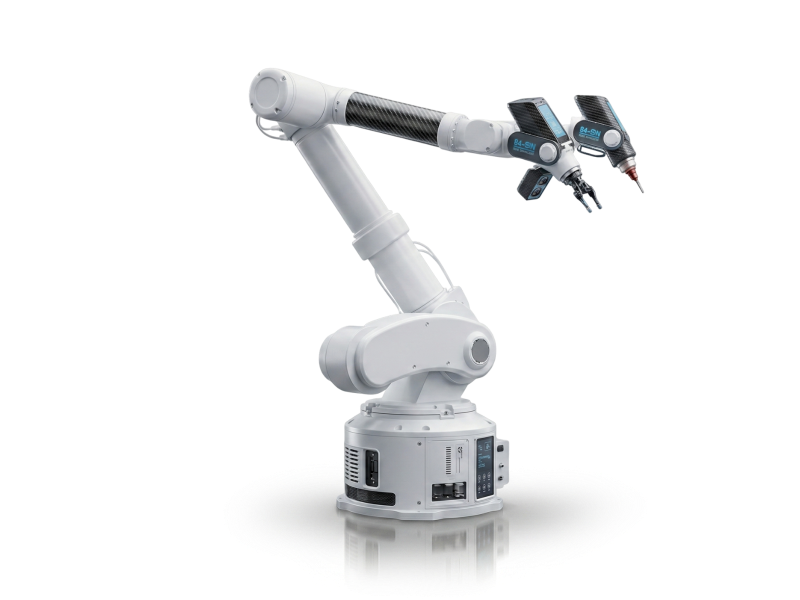
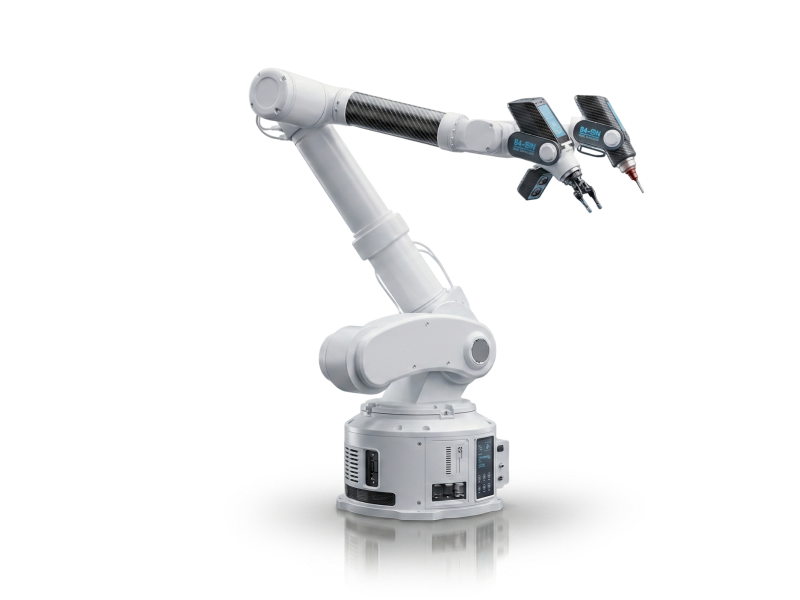
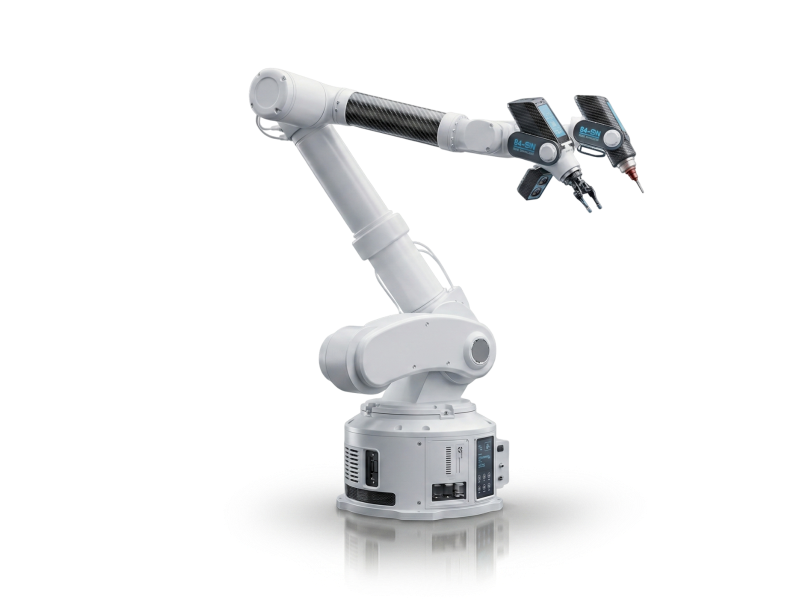
The Titan-X6 Ultra High-Precision Industrial Robotic Arm (Model: YHG-IND-X6) represents the next generation of heavy-duty factory automation. Specifically engineered to meet the rigorous demands of modern smart manufacturing, the Titan-X6 excels in transforming complex, high-intensity, and highly repetitive tasks into seamless, autonomous workflows.
Uncompromising Mechanical Rigidity: Constructed from aviation-grade aluminum alloy and high-strength carbon composites, the structural integrity minimized kinetic deflection even during full-speed, maximum-load cycles.
Seamless Eco-System Integration: Features plug-and-play compatibility with standard industrial fieldbuses (EtherCAT, PROFINET, Modbus-TCP), allowing rapid deployment into existing automotive assembly lines, CNC machining centers, and automated electronics packaging systems.
Next-Gen Kinematic Algorithms: Powered by our proprietary MotionControl V4.0 engine, the arm automatically calculates optimal acceleration curves, reducing mechanical wear-and-tear by 30% and cutting cycle times significantly.
Specification
Parameter / Feature
Unit
Value
Test Condition / Standard
Description
Model Number
–
YHG-IND-X6
Factory Standard
Product series identification code.
Number of Axes
–
6
–
Articulated structure for full 3D spatial motion.
Nominal Payload
kg
25
Rated continuous load
Maximum mass allowed at the wrist flange at full speed.
Maximum Reach
mm
1850
Center of Axis 1 to Axis 6
Maximum horizontal operating radius of the robotic arm.
Pose Repeatability
mm
±0.02
ISO 9283
Deviation of repeated position commands at full speed and load.
Distance Accuracy
mm
±0.05
ISO 9283
Precision of absolute positioning within the working envelope.